I am currently a Master student at the VDI Center, ShanghaiTech University, under the supervision of Prof. Ye Shi, who is an expert in the field of Optimization, Generative Models, Reinforcement Learning, and Embodied AI. I received my B.E. degree from Zhengzhou University.
My Research interest include Embodied AI, Legged Robots and Simulation infrastructure. I am looking for internship and full-time opportunities in these areas. If you are interested in my research or want to collaborate with me, please feel free to contact me! You can find my Curriculum Vitae here.
Email: fanyahao AT shanghaitech DOT edu DOT cn
📝 Publications
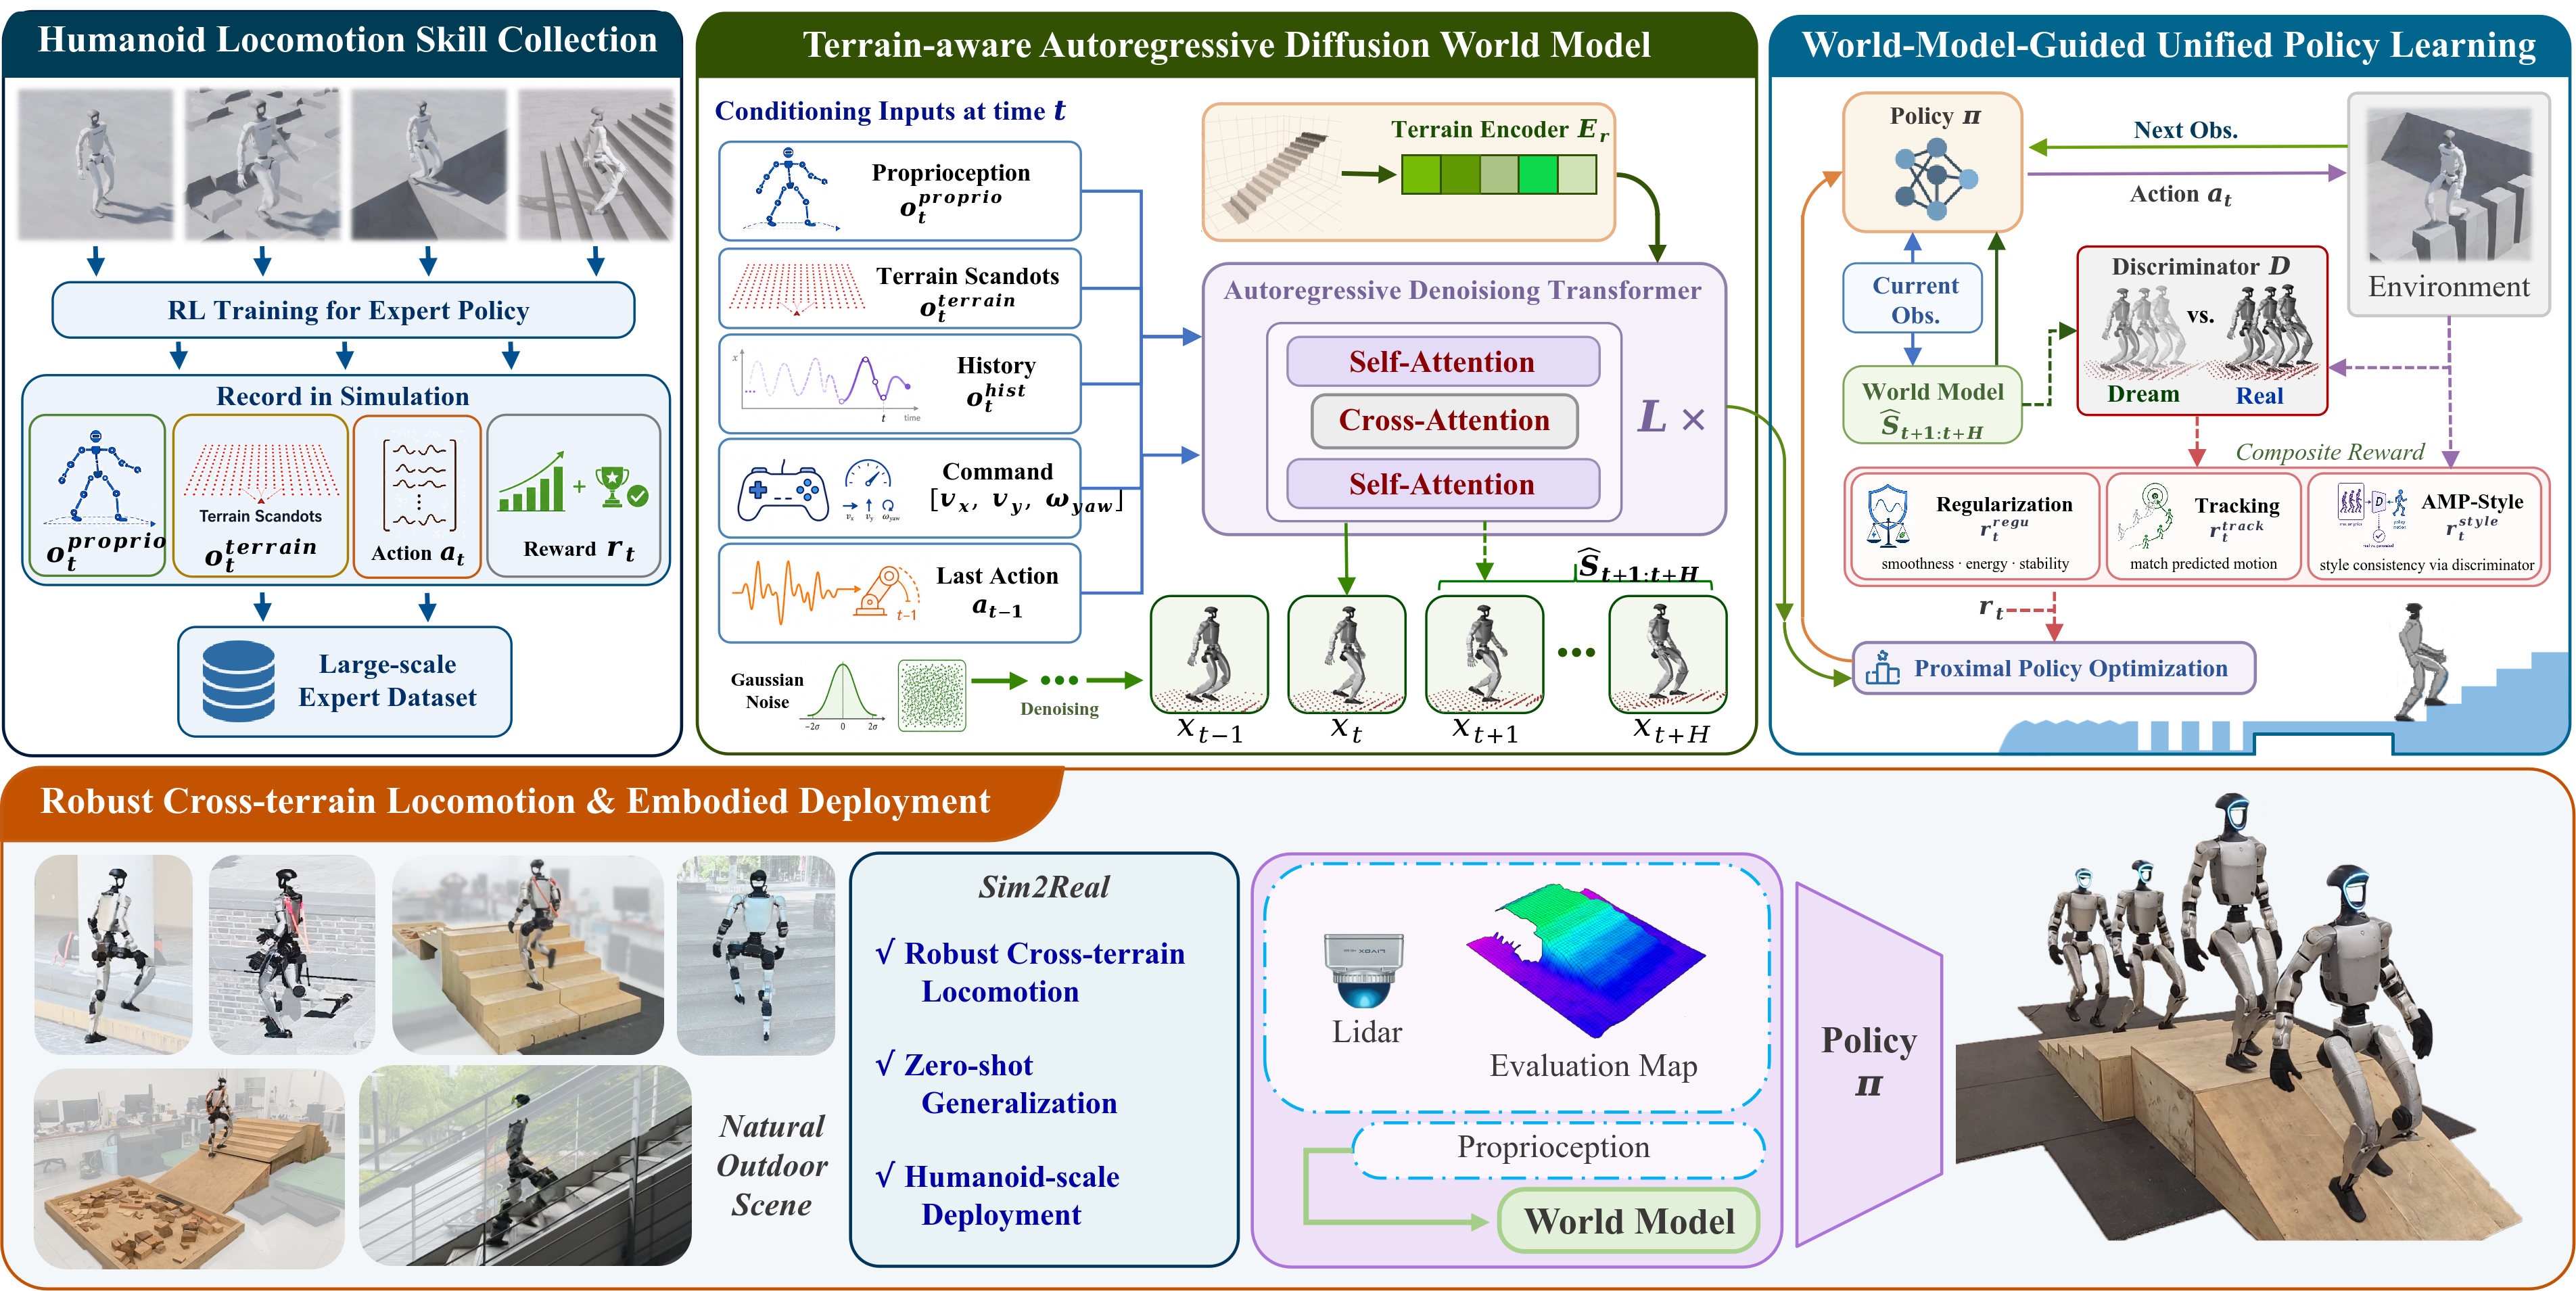
DreamPolicy: A Unified World-model Policy for Scalable Humanoid Locomotion, ArXiv.
Yahao Fan#, Tianxiang Gui#, Kaiyang Ji#, Shutong Ding, Chixuan Zhang, Yifeng Xu, Ke Yang, Jiayuan Gu, Jingyi Yu, Jingya Wang, Ye Shi*
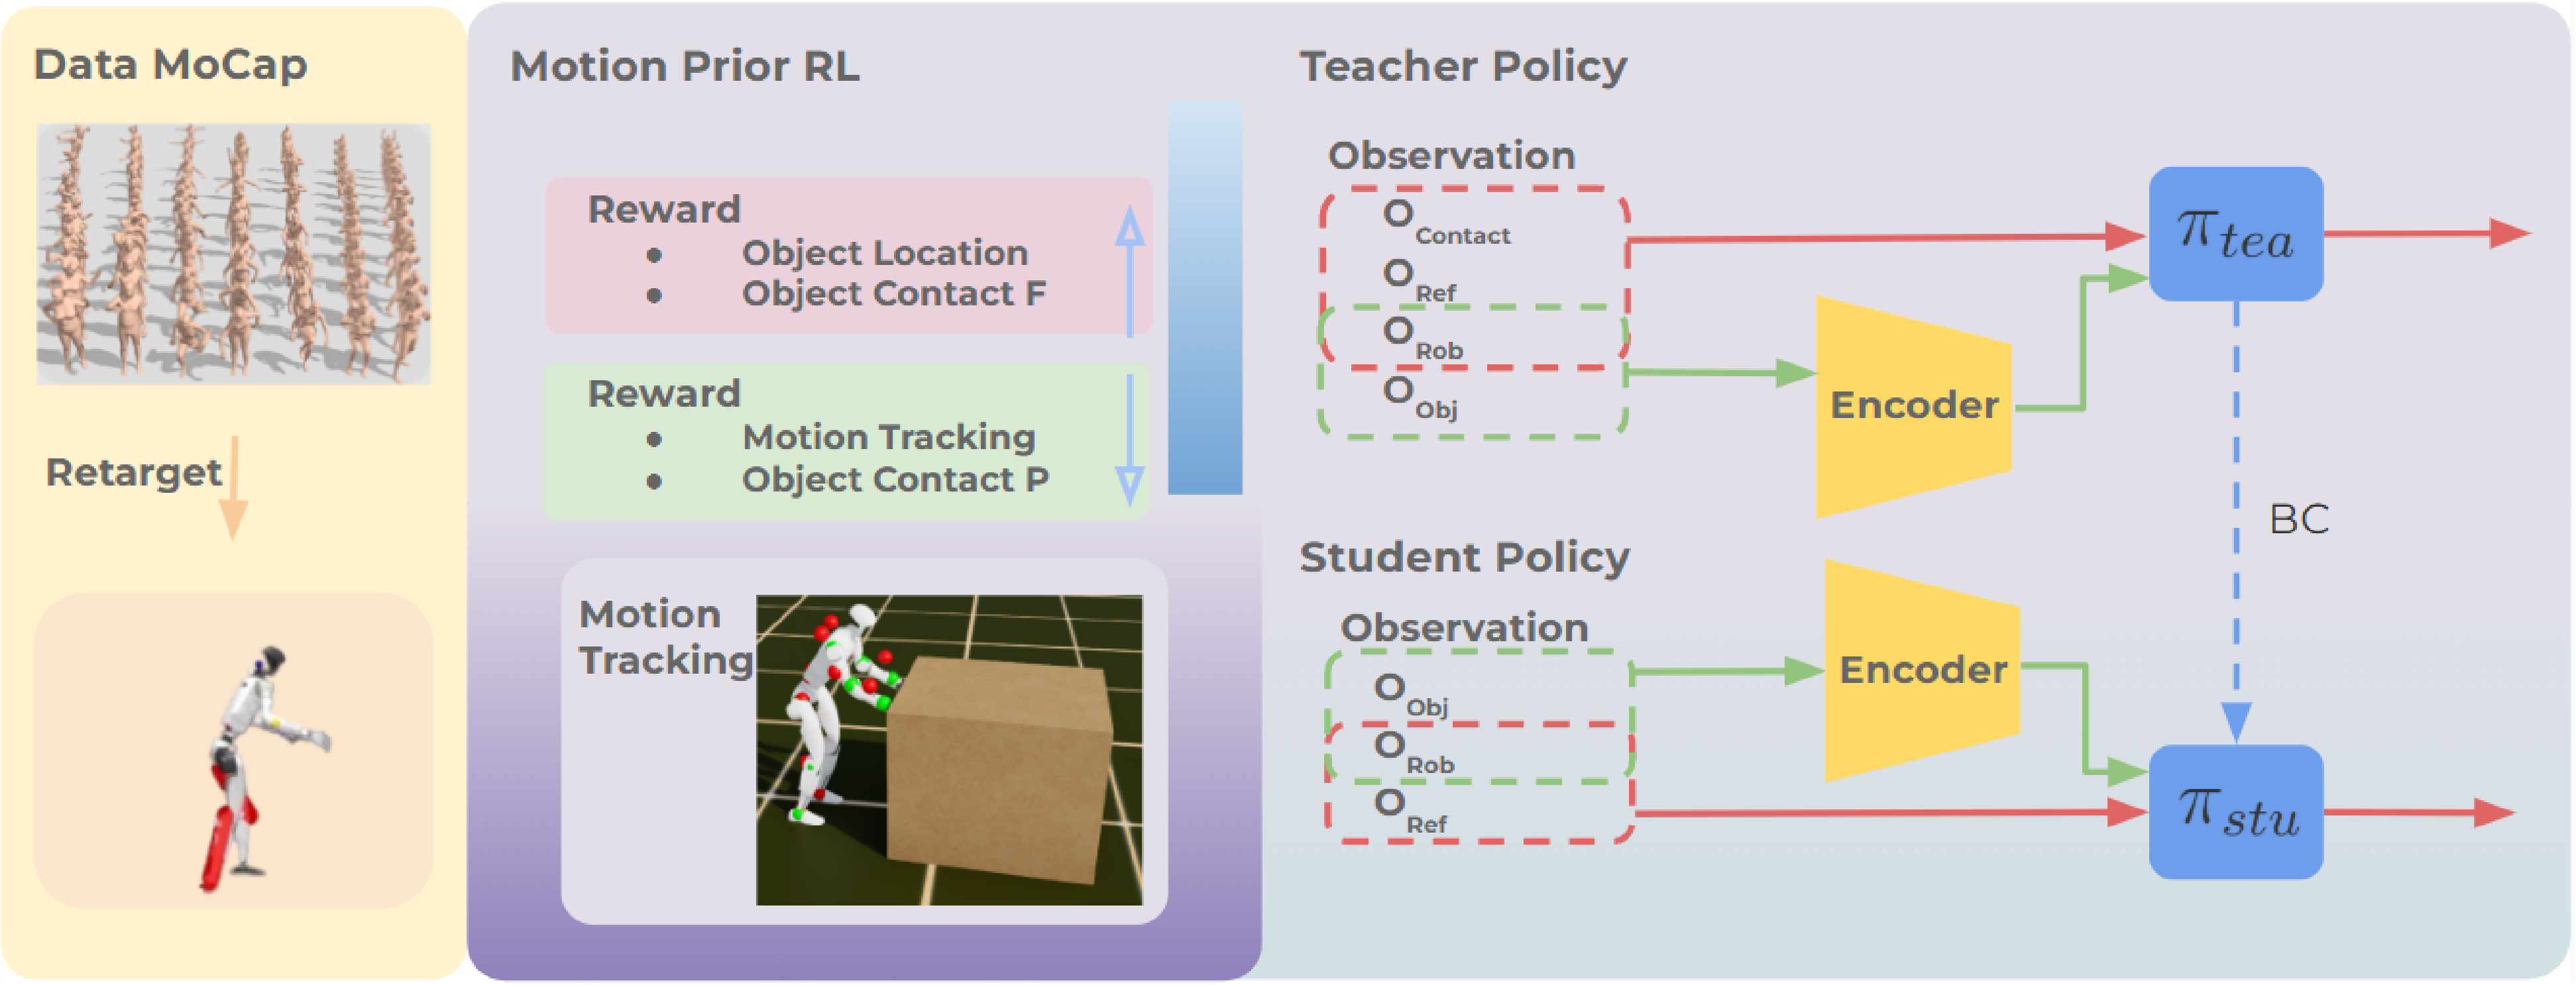
Sisyphus: An attention-driven humanoid object interaction policy, IROS 2025 Workshop: Augmentative Human–Robot Interaction.
Tianxiang Gui, Ke Yang, Yahao Fan, Chixuan Zhang, Jingya Wang*, Ye Shi*
📖 Educations
- 2024.09 - now, ShanghaiTech University, School of Information Science and Technology, major in Computer Technology
- 2020.09 - 2024.06, Zhengzhou University, major in Computer Science and Technology
💻 Internships
Reinforcement Learning Motion Control Intern · AgiBot (智元创新)
2026.07 - Present · Central R&D Department
- Led the Lingxi X2 REACT framework pre-research and embodiment adaptation, migrating the diffusion generator and tracker from PARC to the Lingxi series.
- Reproduced DreamPolicy on Lingxi X2, closing the training - generation - deployment loop of a unified multi-terrain locomotion policy with over 95% success rate on complex terrain.
Embodied AI RL Motion Control Algorithm Intern · GigaAI (极佳视界)
2026.03 - 2026.07 · Large Model Architecture Department
- Led the GigaBrain-PingPong project: multi-embodiment humanoid training framework, unified task modeling, and ball-trajectory prediction with hit-recovery control, reaching over 99% simulated hit success.
- Deployed on Unitree G1 and GigaAI Maker L01 with 132 consecutive human-robot rallies, a record for humanoid table tennis, featured in GigaAI’s official announcement and shown at WRC 2026.
- 2024.03 - 2024.09, Visiting Student, ShanghaiTech University, VDI Center, YesAI Lab
🛠 Skills
| Programming | Python, C++, Git, Bash, Markdown |
| Algorithms & Frameworks | Reinforcement Learning (PPO, AMP, PULSE), DAgger, Imitation Learning, ROS / ROS2 |
| Robotics | Rigid-body kinematics and dynamics, FK / IK solving, Pinocchio |
| Simulation | Isaac Lab, Isaac Gym, MuJoCo, Genesis, Domain Randomization |
| Robot Platforms | AgiBot Lingxi X2, Unitree G1, Unitree H1 / H1-2, Booster T1, Unitree Go2 |
🏆 Honors and Awards
- 2022, Second Prize, RoboCup China (FIRA Small-Size League, Soccer Robot), Zhengzhou University
- 2022, Second Prize, RoboCup China (Simulation 2D League, Soccer Robot), Zhengzhou University
🌍 Community
- 2026, WRC 2026 — demonstrated the GigaBrain-PingPong humanoid table tennis system on site.
- 2025, ICCV 2025 Challenge Organizer — built the multi-terrain locomotion benchmark platform, evaluation environments, and rules.
- 2025, GDPS 2025 Robotics Showcase — invited to demonstrate reinforcement-learning-driven humanoid dance.
- Contributor to the InstinctLab, GenesisLab, and Newton Physics Engine open-source communities.